Loading...
Searching...
No Matches
manifold.hpp File Reference
TODO: Brief description of the file's purpose. More...
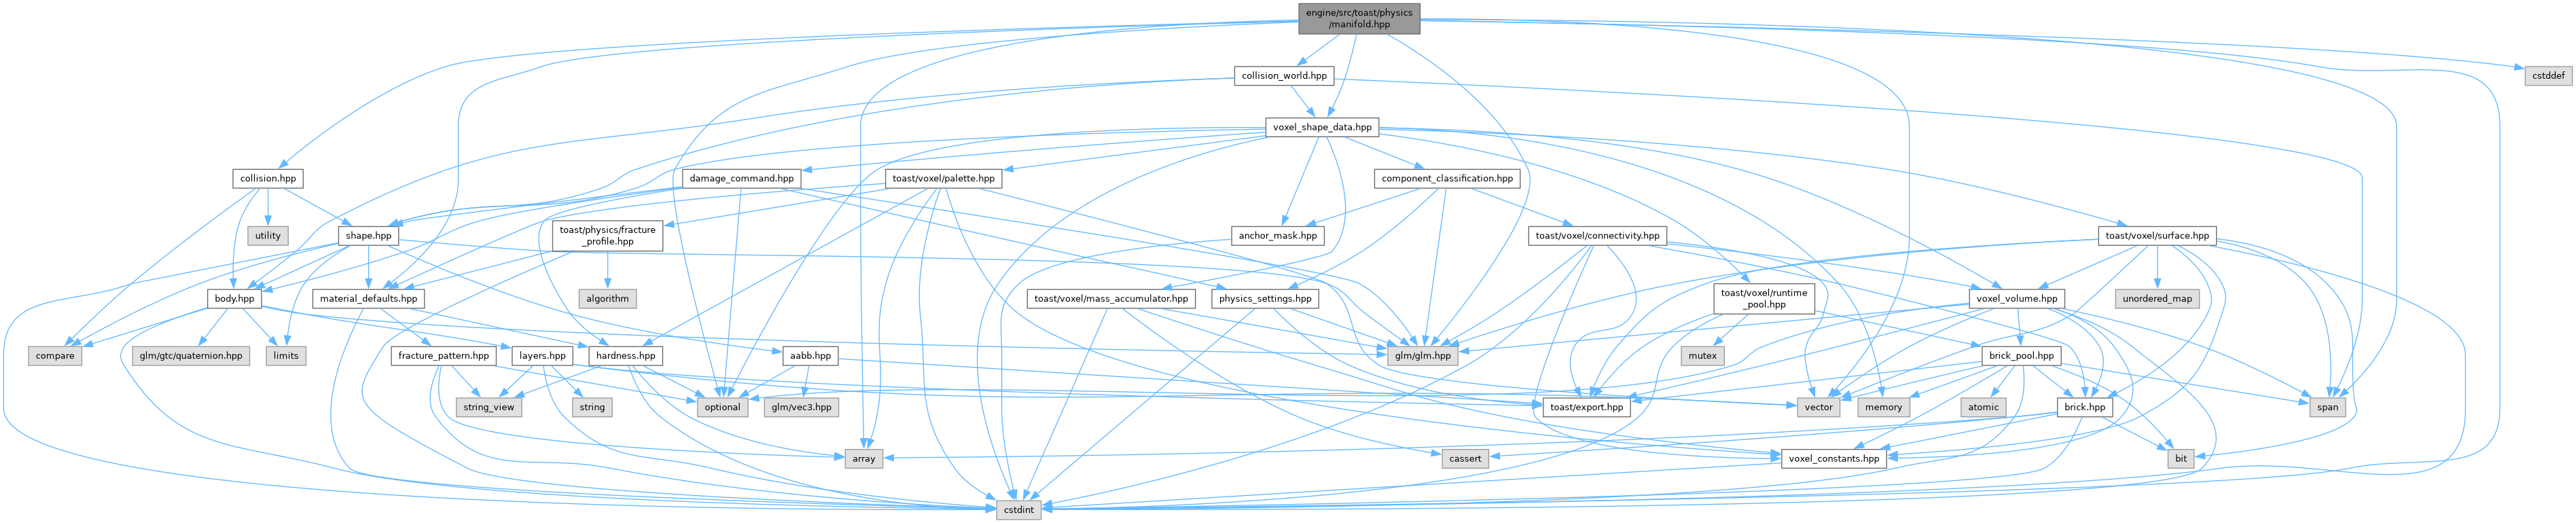
#include "collision.hpp"#include "collision_world.hpp"#include "material_defaults.hpp"#include "voxel_shape_data.hpp"#include <array>#include <cstddef>#include <cstdint>#include <glm/glm.hpp>#include <optional>#include <span>#include <vector>
Include dependency graph for manifold.hpp:
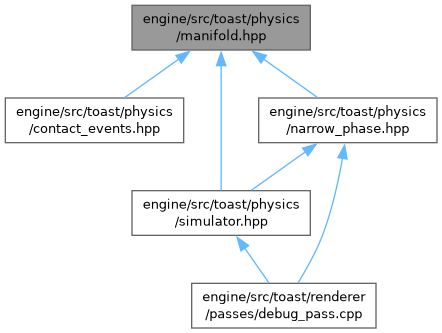
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Enumerations | |
| enum class | BoxFeatureType : uint8_t { interior , face , edge , vertex } |
Functions | |
| auto | physics::operator< (const Manifold &lhs, const Manifold &rhs) -> bool |
| auto | physics::_detail::boxFeature (const glm::vec3 &point, const glm::vec3 &half_extents) -> BoxFeature |
| auto | physics::_detail::contactFeature (const BoxFeature &feature) -> ContactFeatureID |
| auto | physics::_detail::worldSphere (const Body &body, const SphereShape &sphere) -> WorldSphere |
| auto | physics::_detail::worldCapsule (const Body &body, const CapsuleShape &capsule) -> WorldCapsule |
| auto | physics::_detail::worldBox (const Body &body, const BoxShape &box) -> WorldBox |
| auto | physics::_detail::closestPointOnSegment (const glm::vec3 &point, const glm::vec3 &segment_a, const glm::vec3 &segment_b) -> SegmentClosestPoint |
| auto | physics::_detail::closestPointsBetweenSegments (const glm::vec3 &a0, const glm::vec3 &a1, const glm::vec3 &b0, const glm::vec3 &b1) -> SegmentClosestPoints |
| auto | physics::_detail::closestPointOnBox (const glm::vec3 &point, const WorldBox &box) -> glm::vec3 |
| auto | physics::_detail::closestPointsSegmentBox (const glm::vec3 &segment_a, const glm::vec3 &segment_b, const WorldBox &box) -> SegmentBoxClosestPoints |
| auto | physics::_detail::closestPointsSegmentAabb (const glm::vec3 &local_a, const glm::vec3 &local_b, const glm::vec3 &half_extents) -> SegmentAabbClosestPoints |
| auto | physics::_detail::capsuleVoxelContact (const glm::vec3 &segment_a, const glm::vec3 &segment_b, float radius, const glm::vec3 &voxel_min, uint8_t normal_index) -> std::optional< CapsuleVoxelContact > |
| auto | physics::_detail::perpendicularTo (const glm::vec3 &segment) -> glm::vec3 |
| auto | physics::_detail::combineMaterials (const PhysicsMaterial &a, const PhysicsMaterial &b) -> ContactMaterial |
| auto | physics::_detail::surfaceMaterial (const voxel::PhysicalMaterial &material) -> PhysicsMaterial |
| auto | physics::resolveBoxVoxelPair (CollisionWorldView world, BroadPhasePair pair) -> std::optional< BoxVoxelPairView > |
| auto | physics::classifyBoxVoxelSplit (const BoxVoxelPairView &view) -> BoxVoxelSplitInfo |
| auto | physics::splitVoxelRegions (const AABB &local_bounds, size_t region_count) -> std::vector< AABB > |
| Splits local_bounds along its longest axis into up to region_count voxel-aligned, non-overlapping AABBs. | |
| auto | physics::collideBoxVoxelRegion (const BoxVoxelPairView &view, const AABB ®ion) -> VoxelPairPartial |
| void | physics::mergeBoxVoxelPartials (BroadPhasePair pair, const BoxVoxelPairView &view, std::span< VoxelPairPartial > partials, std::vector< Manifold > &output) |
| auto | physics::resolveVoxelVoxelPair (CollisionWorldView world, BroadPhasePair pair) -> std::optional< VoxelVoxelPairView > |
| auto | physics::classifyVoxelVoxelSplit (const VoxelVoxelPairView &view) -> std::optional< VoxelVoxelSplitInfo > |
| nullopt means the bounds do not actually overlap, distinct from a present-but-zero estimate | |
| auto | physics::collideVoxelVoxelRegion (const VoxelVoxelPairView &view, const AABB &probe_region) -> VoxelPairPartial |
| void | physics::mergeVoxelVoxelPartials (BroadPhasePair pair, const VoxelVoxelPairView &view, std::span< VoxelPairPartial > partials, std::vector< Manifold > &output) |
| auto | physics::collideSpheres (BroadPhasePair pair, CollisionElement a, CollisionElement b) -> std::optional< Manifold > |
| auto | physics::collideSphereBox (BroadPhasePair pair, CollisionElement sphere_element, CollisionElement box_element) -> std::optional< Manifold > |
| auto | physics::collideSphereCapsule (BroadPhasePair pair, CollisionElement sphere_element, CollisionElement capsule_element) -> std::optional< Manifold > |
| void | physics::collideSphereVoxel (BroadPhasePair pair, CollisionElement sphere_element, CollisionElement voxel_element, const VoxelShapeData &voxel_data, std::vector< Manifold > &output) |
| auto | physics::collideBoxes (BroadPhasePair pair, CollisionElement a, CollisionElement b) -> std::optional< Manifold > |
| void | physics::collideBoxVoxel (BroadPhasePair pair, CollisionElement box_element, CollisionElement voxel_element, const VoxelShapeData &voxel_data, std::vector< Manifold > &output) |
| auto | physics::collideCapsuleBox (BroadPhasePair pair, CollisionElement capsule_element, CollisionElement box_element) -> std::optional< Manifold > |
| void | physics::collideCapsuleVoxel (BroadPhasePair pair, CollisionElement capsule_element, CollisionElement voxel_element, const VoxelShapeData &voxel_data, std::vector< Manifold > &output) |
| auto | physics::collideCapsules (BroadPhasePair pair, CollisionElement a, CollisionElement b) -> std::optional< Manifold > |
| void | physics::collideVoxelVoxel (BroadPhasePair pair, CollisionElement a, const VoxelShapeData &data_a, CollisionElement b, const VoxelShapeData &data_b, std::vector< Manifold > &output) |
Detailed Description
TODO: Brief description of the file's purpose.
- Date
- 10 Sep 2026
